Engineering Deployments
Verified perception, kinematics, and gripping frameworks for field and industrial platforms.
How We Partner
01
Technological Licensing & Adaptation
We provide architectural consulting to adapt and license our proprietary vision, kinematic, and cognitive cores for manufacturer and laboratory platforms, delivering custom initial feasibility blueprints tailored to your operational framework.
02
Custom Mechatronic Architecture
We design and integrate custom software-defined hardware layers, charging milestone-based development and engineering setup fees to build robust prototypes optimized for your specific environments.
03
Enterprise Edge Deployment
We orchestrate secure, cloud-agnostic systems localized directly at your infrastructure in North America, supporting persistent reliability for research and industrial partners.
+
#
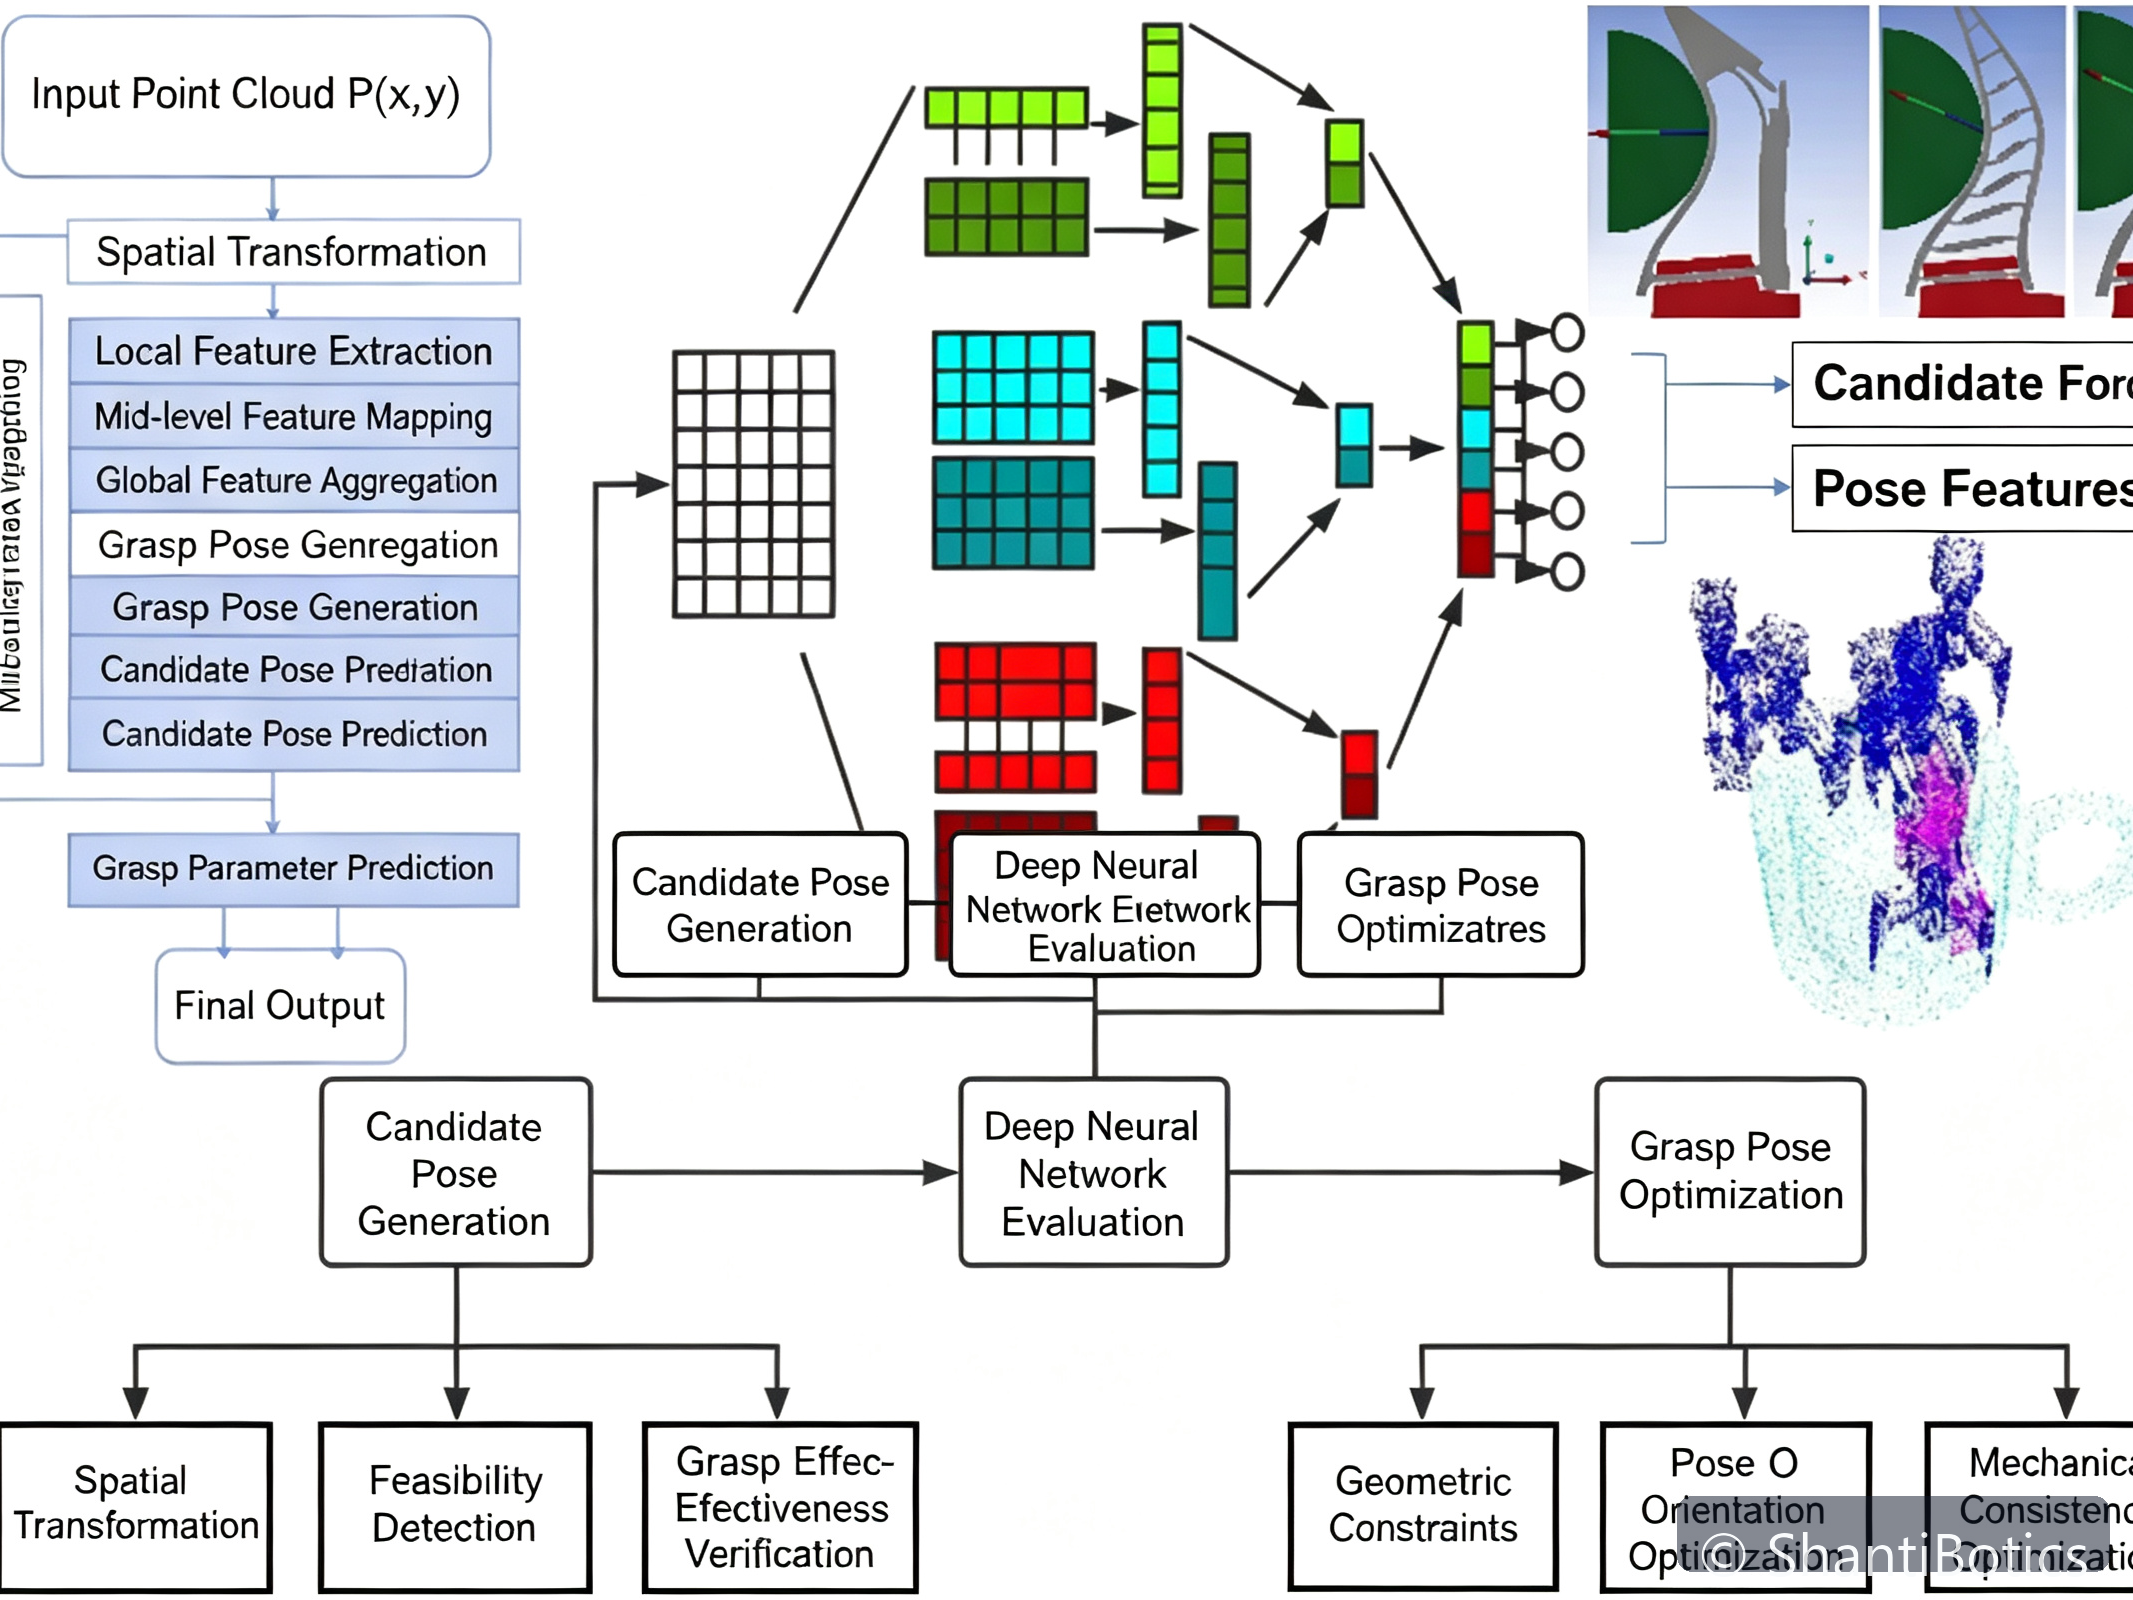
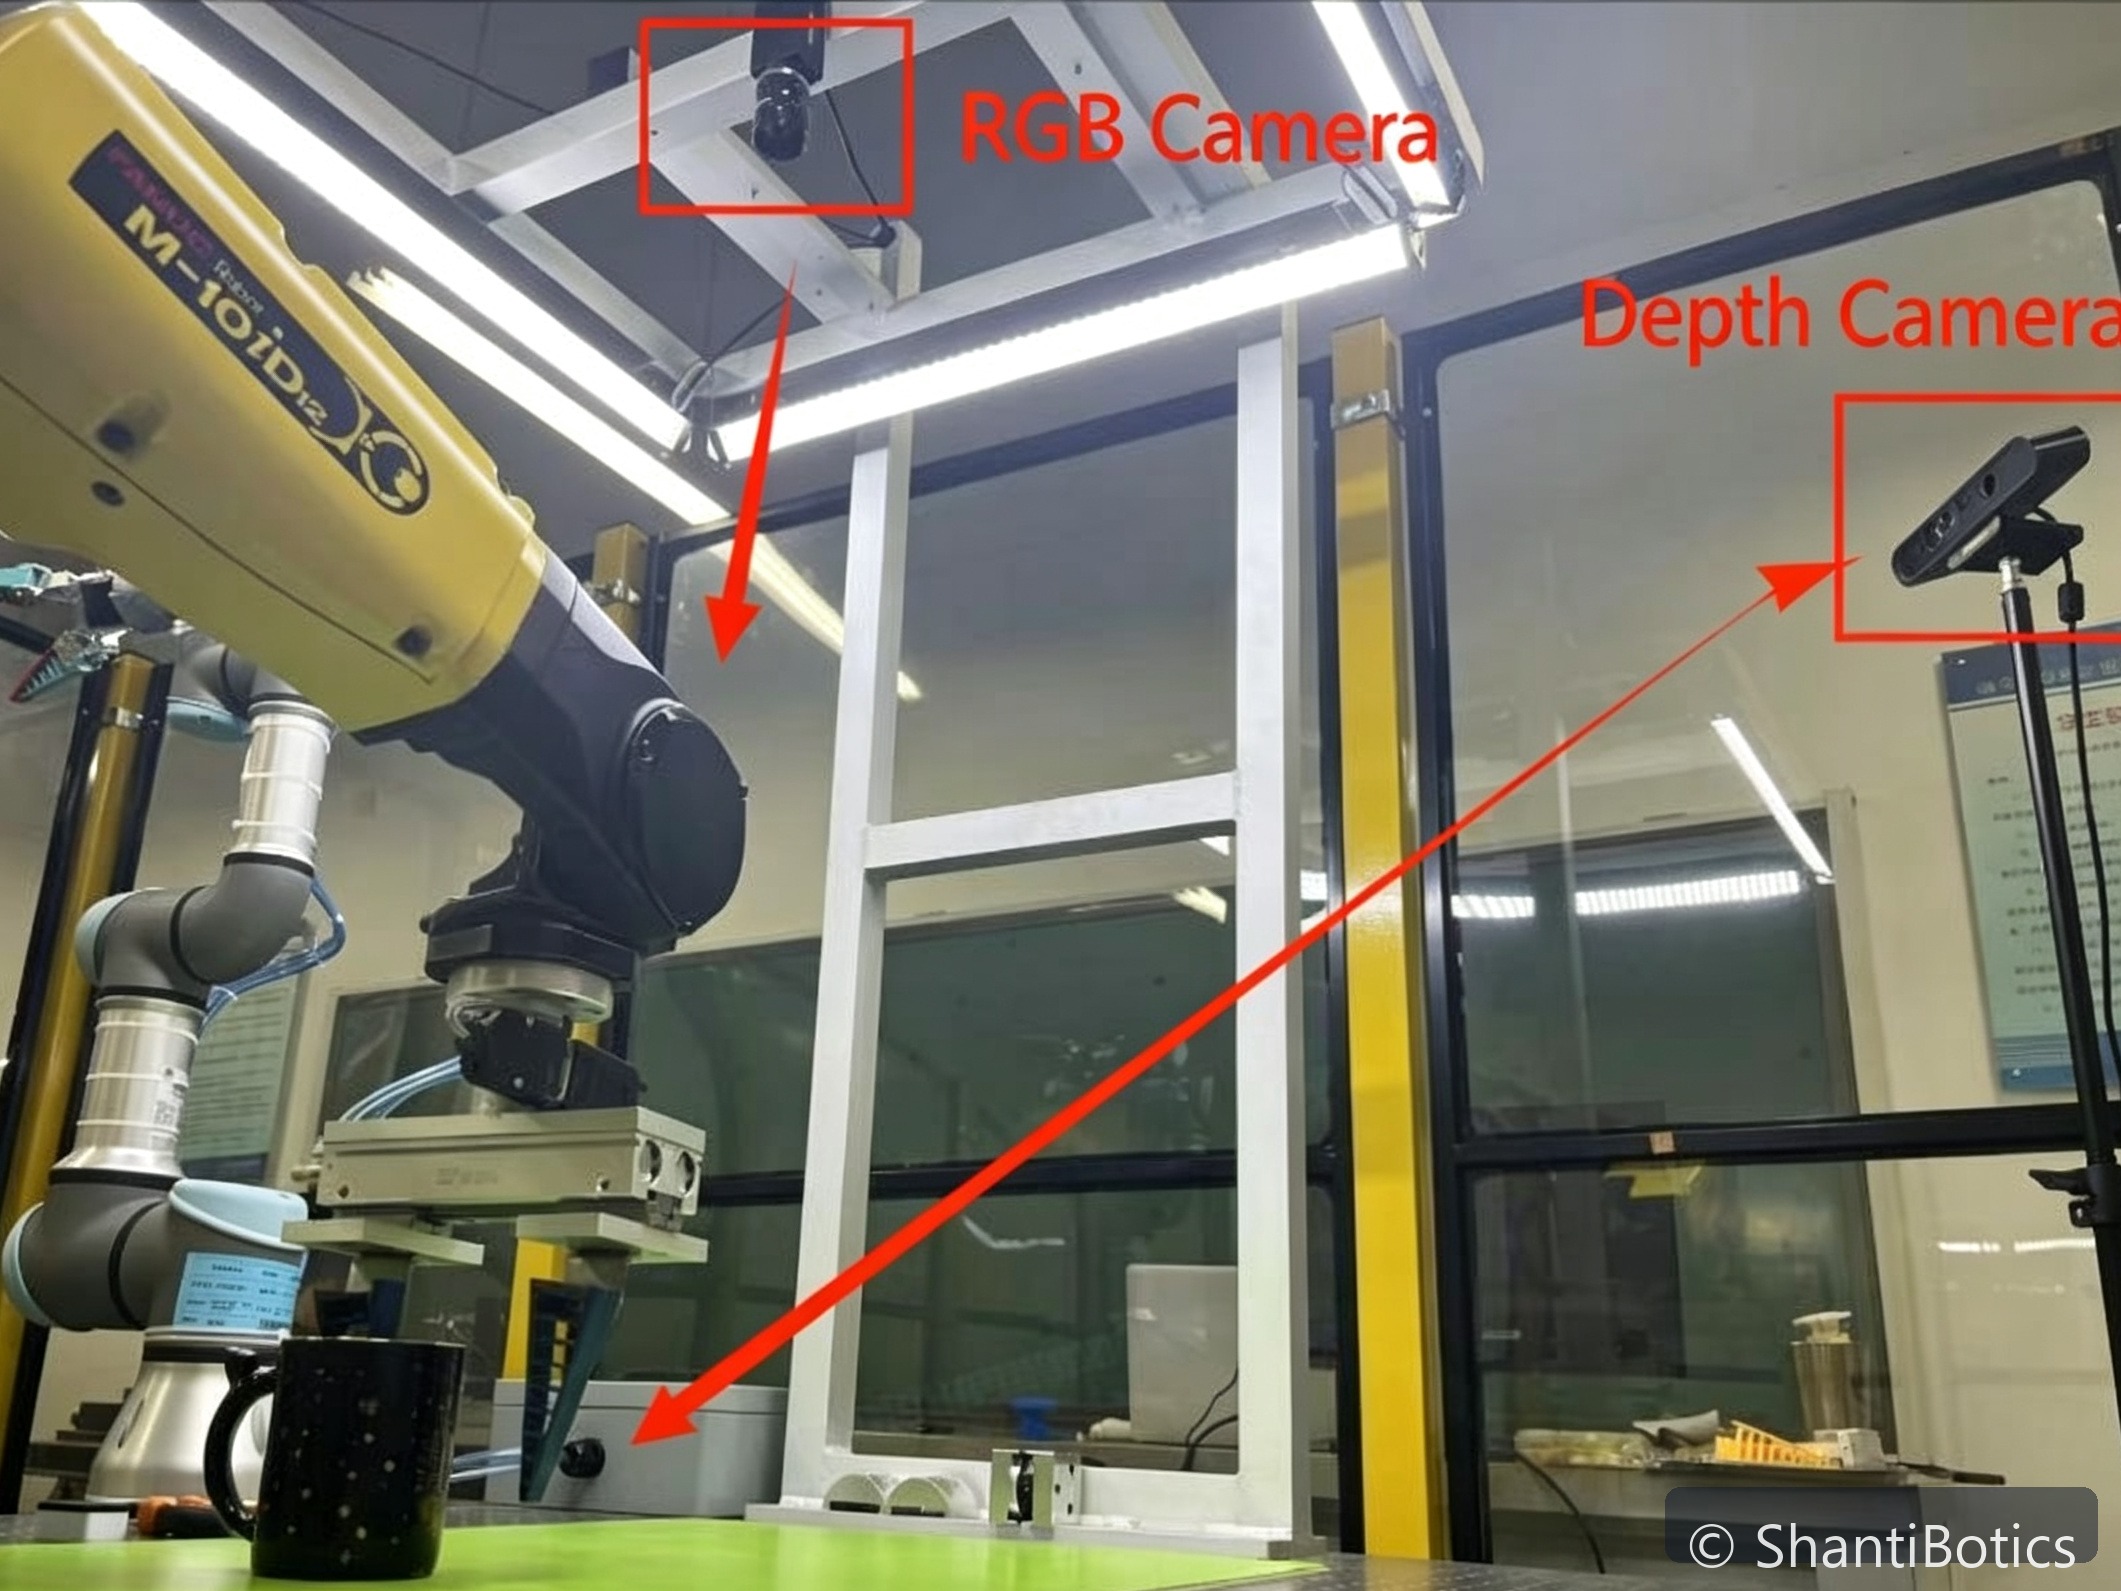
Vision-Guided Perception
Intelligent Vision-Guided Perception Frameworks
Vision-Guided Target Perception & Adaptive Manipulator Control
+
#
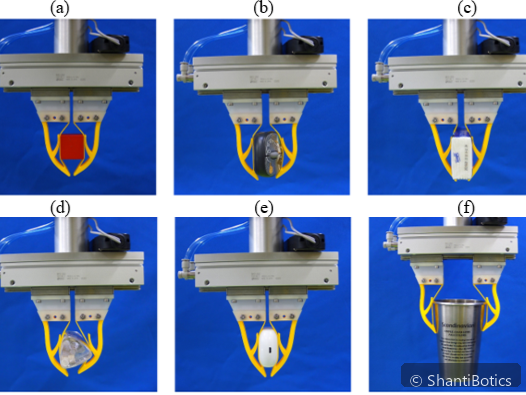
Adaptive Gripping & Compliant Robotics
Compliant Mechanisms & Intelligent Adaptive Gripping
Vision-Guided End-Effectors for Delicate Object Handling
+
#
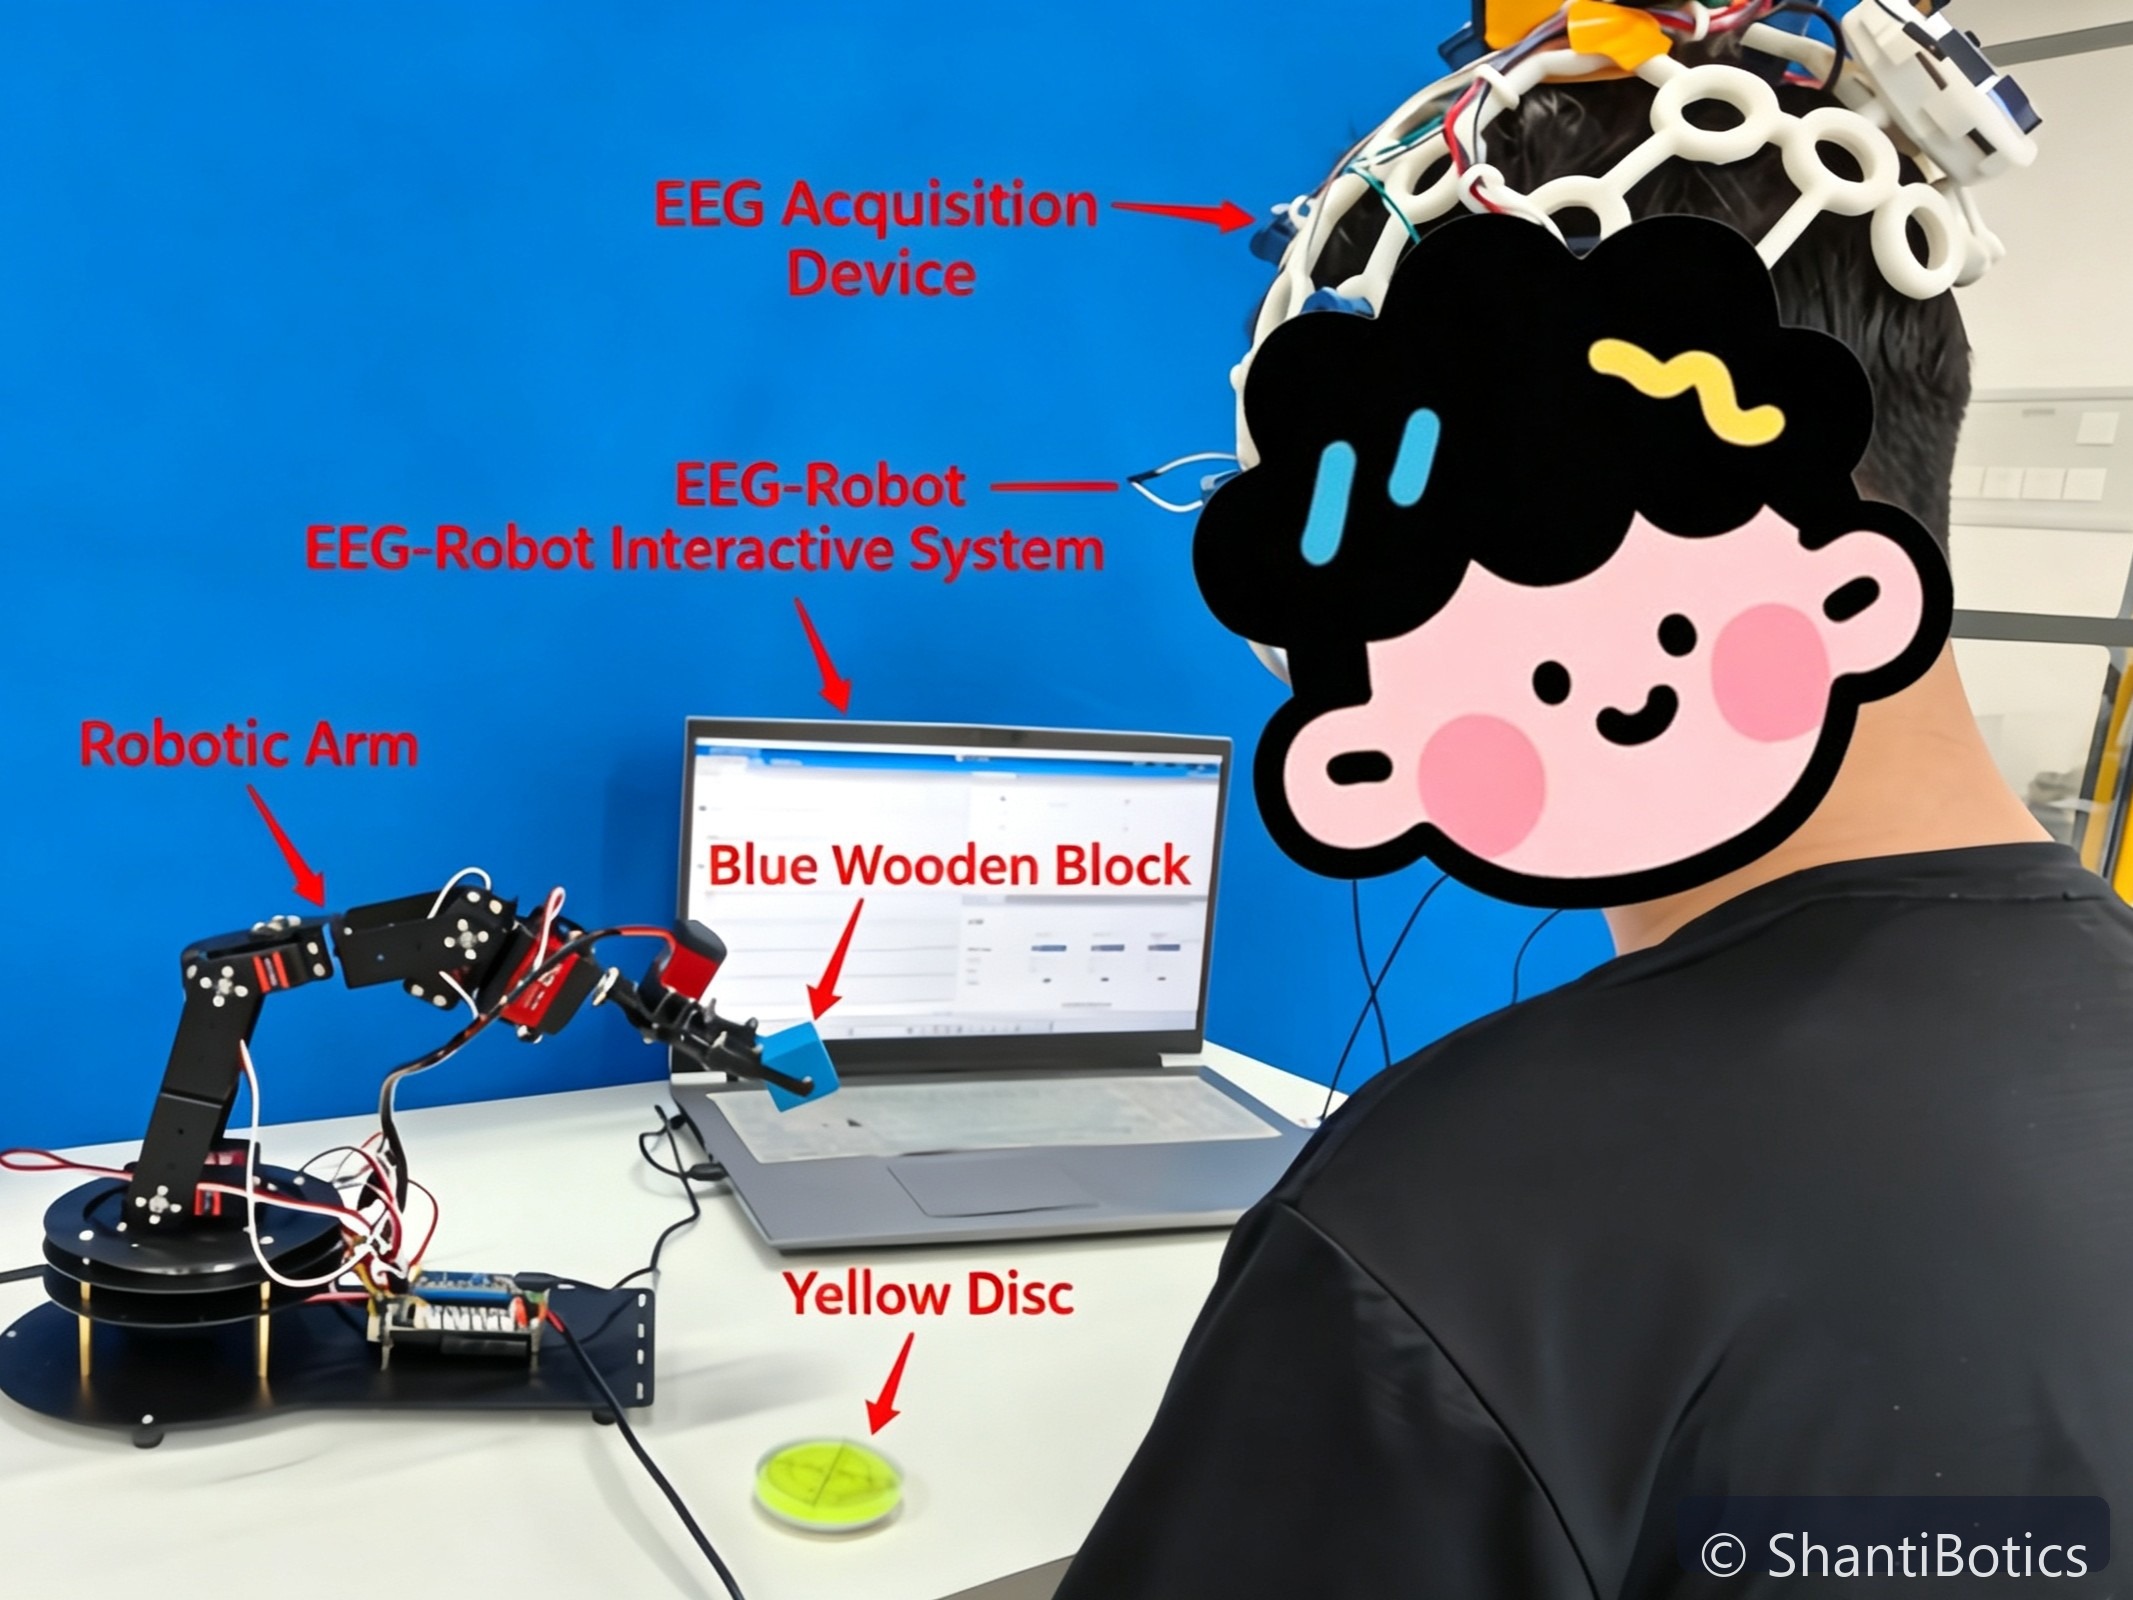
Brain-Computer Interaction & Neuro-Mechatronics
Brain-Computer Interaction for Robotic Grasp Control
Neural Intent Decoding That Drives Manipulator Grasp & Place